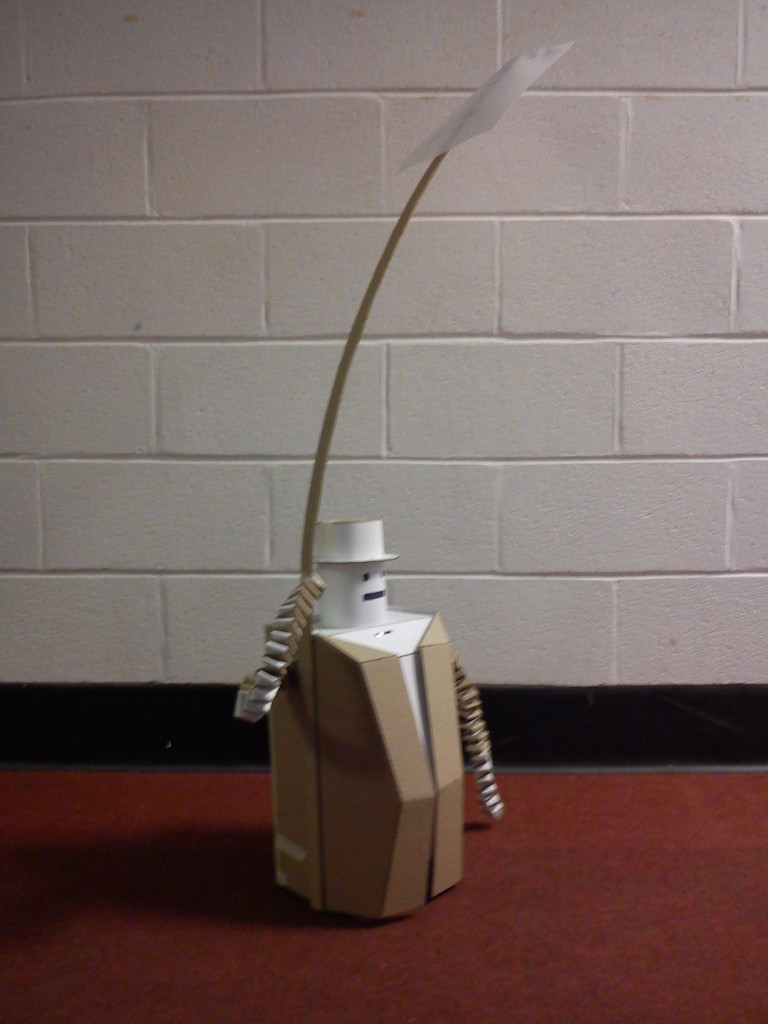
I have now embedded all my electronics and here is the working tech prototype hand in for PLAY. Although it does still have some mechanical issues which need smoothing over. Primarily the front wheel, which is a ball bearing, isn’t as smooth as it was and keeps jamming which causes the robot to stagger about and get stuck. I am hoping that this is not too much of an issue though as it is a mechanical problem and should be easily resolved. I’ll try to see what I can find to replace it tomorrow but not too fussed.
I does also look quite funny!
So what it does is call for help until it receives a donation. It then thanks the donator and begins its journey for around 20 seconds until it stops again and calls for help. I am thinking that it would be nice also if it was trying to get to a specific location so carried a banner highlighting this: